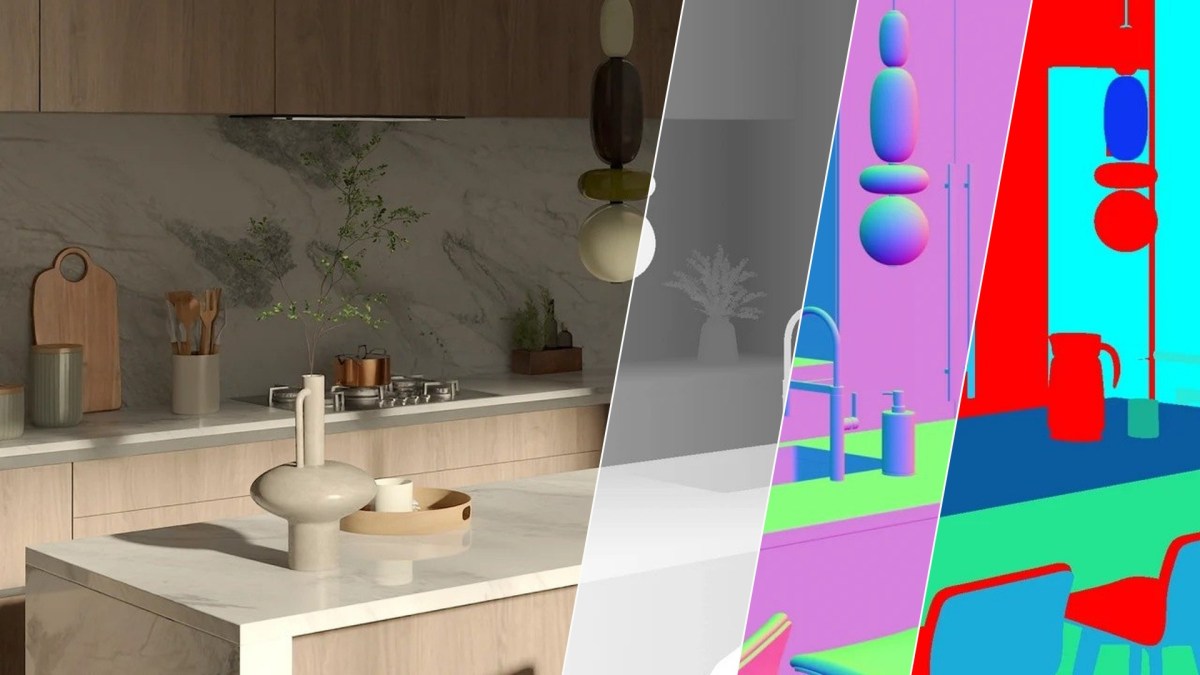
Physicl, a startup founded by Alex de Vigan, raised $10 million in seed funding led by Inovia Capital. The company transforms 3D rendering technology from de Vigan's previous venture, Infinite, into a platform for training robots through high-fidelity simulations.
De Vigan built Infinite over a decade to help brands create 3D product models for e-commerce. When generative AI models rose in prominence, the company shifted toward generative imagery. De Vigan identified a gap in AI: its ability to understand, interact with, and manipulate physical space and objects.
Physicl addresses a training problem for physical AI developers. Researchers building robot models have struggled with the cost and returns of gathering training data through video or remote operations. Simulations offer a solution, but ensuring digital worlds match real-world physics has proven difficult. De Vigan's previous pipeline for converting unstructured real-world information into high-fidelity 3D representations with correct geometry, materials, and physics now applies to robot training.
The startup launches with a product called Studio that includes 10,000 3D environments and 100,000 assets. Users create scenes to generate synthetic data for training robots on specific tasks. For example, Studio can generate training data to help a robot identify a cup on a cluttered countertop or in shadow.
SpAItial, a world model builder, collaborated with Physicl as an early customer. SpAItial's CEO and founder Matthias Niessner, who is also a professor of robotics at the Technical University of Munich, said the company needed high-fidelity synthetic data to train its product Echo-3, released last week. The tool generates 3D simulations from 2D imagery.
De Vigan frames Physicl as more than a data provider. He describes the company as offering an "agentic workflow" that transforms unstructured information into high-quality 3D representations. Customers could feed in trillions of images or millions of hours of lidar data and generate billions of training permutations. Niessner noted the appeal of on-the-fly data generation, where models could auto-generate training data based on what they need mid-training rather than requiring manual curation.